Project film 01
Industrial project
Robotic Arm Automation System
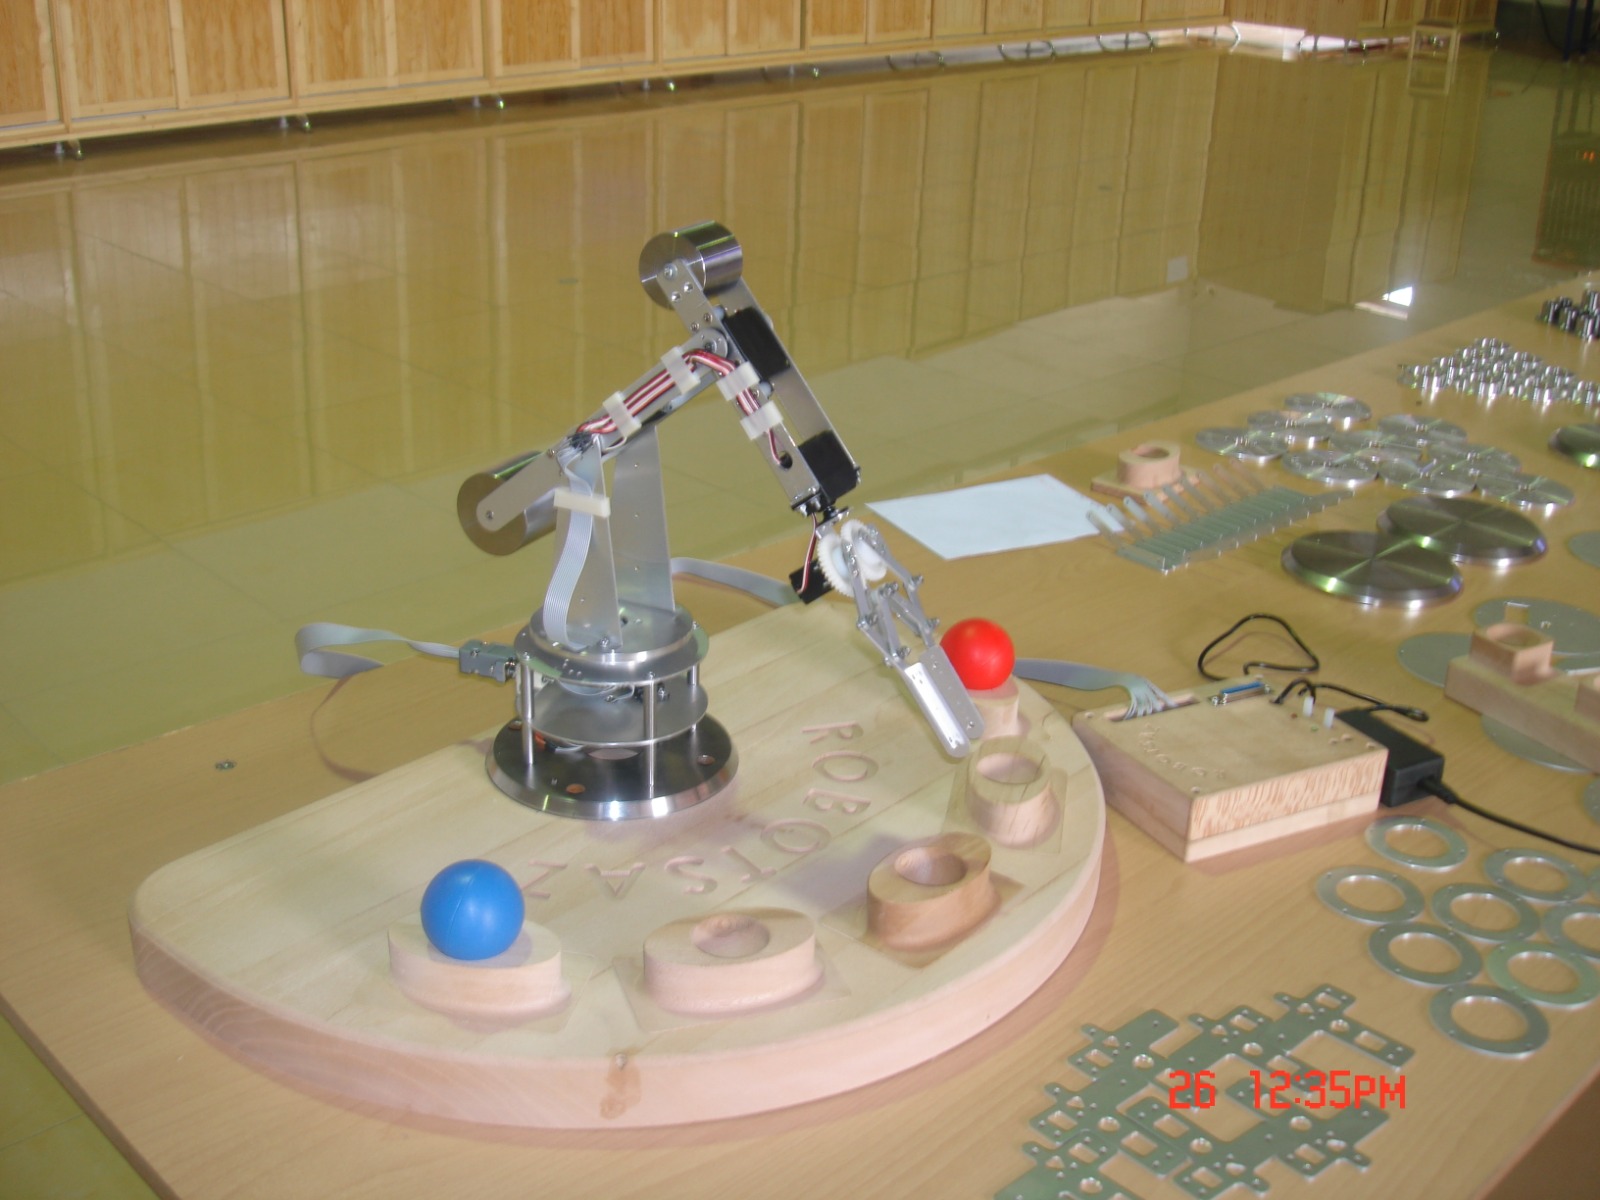
A functional robotic arm designed to demonstrate automated object handling, controlled multi-axis movement, positioning, and pick-and-place operations using an electronic control system.
EngineeringAutomationFabrication
Project brief
The work behind the result.
This robotic arm was designed and manufactured as a functional automation prototype for demonstrating controlled multi-axis motion and object manipulation. The system performs coordinated arm movements for positioning, gripping, picking, transferring, and placing objects within its working area. Its mechanical structure, actuators, control electronics, and gripper were integrated into a complete robotic system. The project demonstrates fundamental industrial robotics concepts including motion control, repeatable positioning, actuator coordination, end-effector operation, and automated material handling. It can be used for robotics demonstrations, engineering education, exhibitions, research, and automation training.
Project videos
See the work in motion.
A closer look at the process and finished result.
More work